Théo Cachet
I was first introduced to imitation and reinforcement learning at Imperial College in 2018, and quickly fell in love with the craft through countless late nights spent training agents for programming competitions such as Halite and Lux AI.
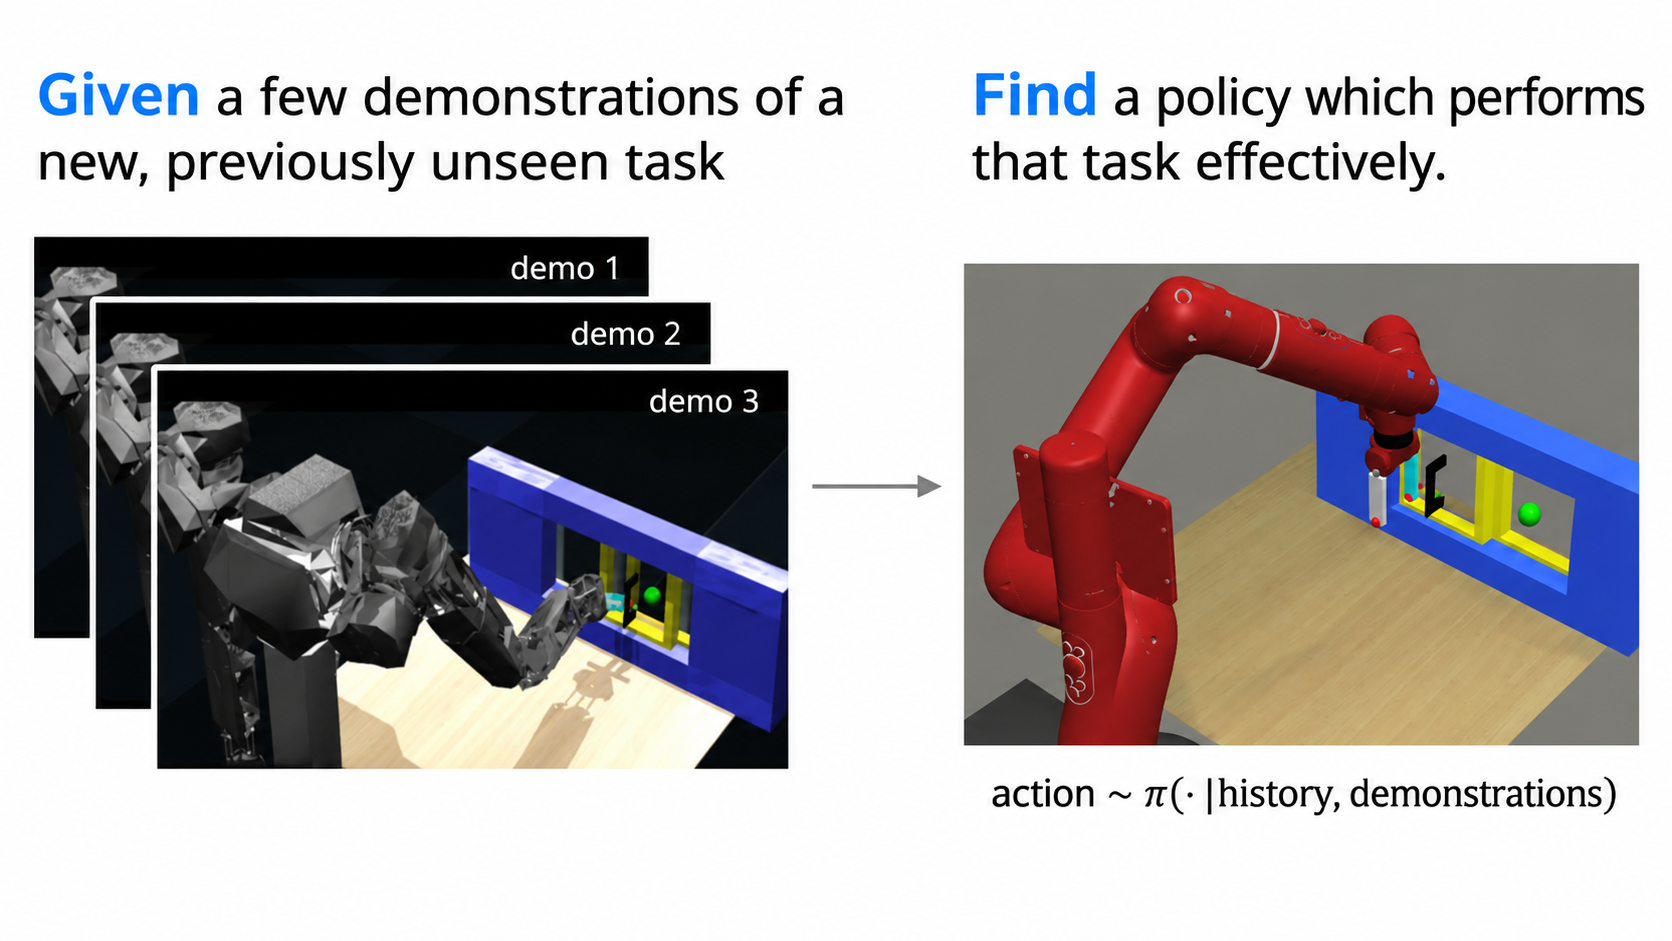
In these challenges, each game starts with random initial conditions and opponents, which motivated me to do a Ph. D in task-level generalization at NAVER LABS Europe and Sorbonne University. I developed novel methods for specifying tasks to agents that significantly improve generalization to new tasks. This research resulted in two first-author ICML papers: one on demonstration-conditioned policies, and another on a retrieval-based alternative to VLAs.
I joined Mistral AI a year ago, and led research on Robostral Navigate, an 8B VLM achieving state-of-the-art performance on R2R and RXR. I worked across the entire stack, spanning VLM/VLA architectures, synthetic data pipelines, evaluation, and deployment on real robots.
Key Research Works
 Watch Demo Video
Robostral Navigate: Vision-Language Navigation via Dual System Architecture
Théo Cachet et al.
A vision-language navigation dual system deployed on real robots across diverse embodiments, achieving SoTA performance on R2R and RXR benchmarks.
 Interactive Demo Available
From Goal-Conditioned to Language-Conditioned Agents via Vision-Language Models
Théo Cachet, Christopher Dance, Olivier Sigaud
Connecting simulator state representations with natural language using rendering functions and VLMs to build zero-shot language-conditioned agents.